Physicl has raised $10 million in seed funding from Inovia Capital to build simulations that teach robots how to handle objects in the real world.
The pivot from e-commerce to robotics
Alex de Vigan spent a decade building nfinite, a platform that allowed brands to generate 3D models of their products for online stores. That business struggled as generative AI took over image creation. De Vigan saw a different use for the technology his team had developed to render 3D environments with high fidelity.
He argues that while AI can create images, it lacks the ability to understand, interact with, and manipulate space and objects in a physical sense. This gap is what Physicl aims to fill.
Researchers working on physical AI models face a persistent problem: training robots to handle diverse, small items using video data often yields poor results. Gathering real-world data through remote operations is also prohibitively expensive.
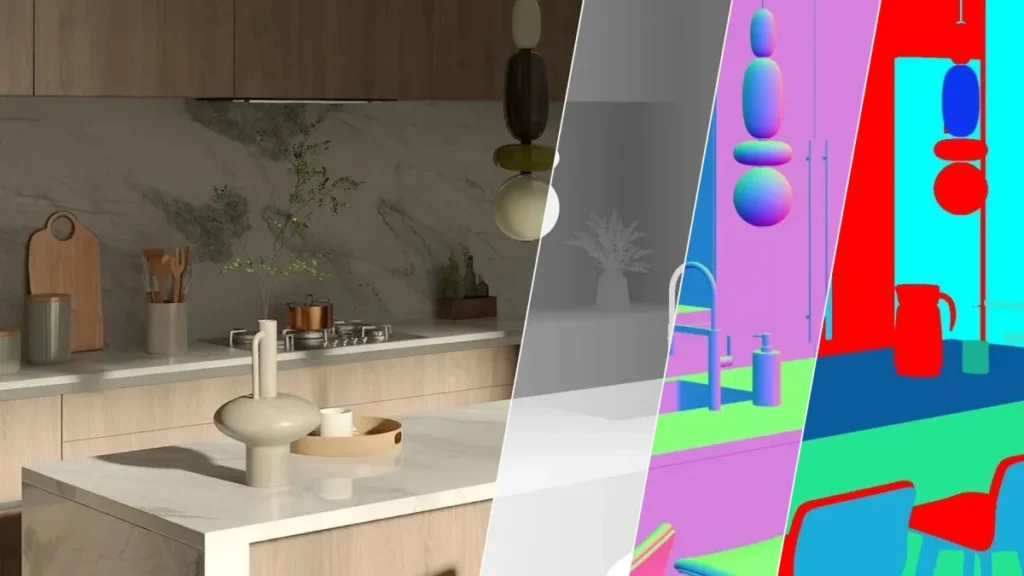
Digital simulations offer a solution, but ensuring those worlds obey real-world physics has proven difficult. De Vigan believes his previous company’s pipeline, which transformed unstructured, incomplete, and heterogeneous real-world information into high-fidelity physical representations with correct geometry, materials, and physics, is now the key to better physical AI models.
A crowded field with blurry lines
The startup enters a competitive category where companies vie to provide data and tooling for foundation model builders and robot operators. De Vigan admits the space is very young and very blurry sometimes.
Physicl intends to focus on post-training models for difficult edge cases. The company is launching a product called Studio, which includes 10,000 3D environments and 100,000 assets representing various objects. Users can create scenes to generate synthetic data for training robots on specific problems.
For instance, Studio could produce training data to help a robot that struggles to discern a cup on a cluttered counter-top, or to identify a cup while it is in shadow.
Early validation with SpAItial
SpAItial, a world model builder, worked with Physicl as an early customer to improve the fidelity of its products. The latest release from SpAItial, Echo-3, came out last week. Its tool generates 3D simulations from 2D imagery, and CEO and founder Matthias Niessner stated they needed the high-fidelity synthetic data Physicl offers to train effectively.
Physicl sees itself as more than a data provider; it views its role as the tooling for ongoing synthetic data generation.
“What we created 10 years ago, without knowing it, was basically an agentic workflow to transform unstructured information into high fidelity 3D,” de Vigan said. He imagines customers bringing trillions of images or millions of hours of LIDAR capture data to feed into the platform. This would turn the inputs into high-quality 3D representations used to generate billions of permutations for model training.
Automating the curation loop
Niessner, also a professor of robotics at the Technical University of Munich, told TechCrunch that the real challenge involves curating data by hand, which is a very long cycle.
To us what seems very attractive is you can just do this on the fly. You’re running Claude, and it checks, ‘Oh, I need more data of this in my training,’ and then it auto generates that data, depending on the training state. That, to me, is super exciting, and this is exactly what Physicl is offering.